XCSoar with PEV start
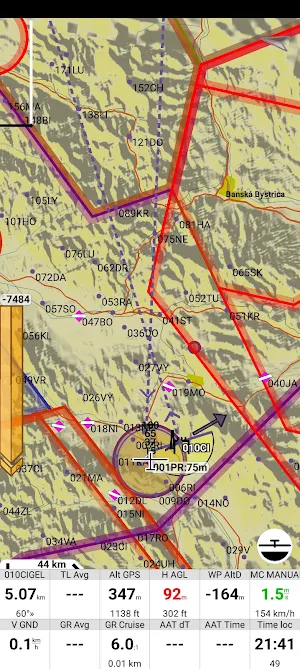
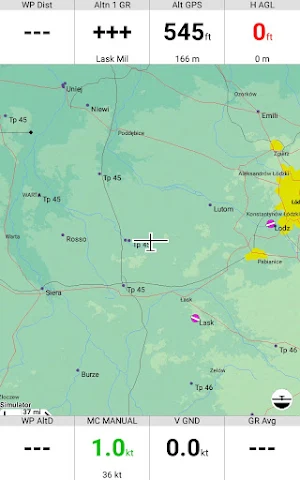
XCSoar gliding navigation software extended with start at PEV option.
Free website generator for mobile apps; privacy policy, app-ads.txt support and more...
AppPage.net
About XCSoar with PEV start
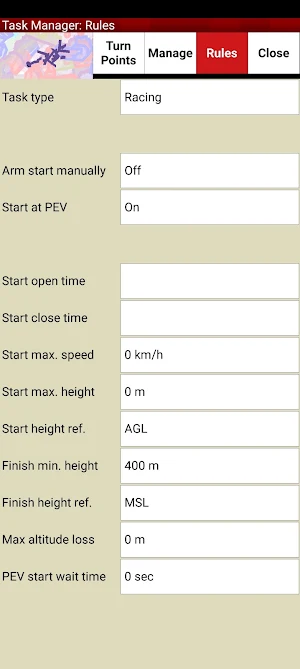
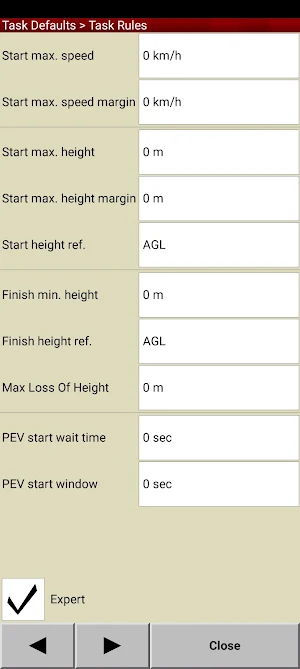
This fork from main XCSoar development implements this type of start. Additionally it allow to setup Maximum Loss of Height between start and finish.
All other functions are the same as in the main XCSoar development track.
This software is an Open Source project.
Source code: https://github.com/marek1313/XCSoar-fork-for-PEV-start
Similar Apps
Drive by Dock Robotics
Professional ROS robot teleoperation — without the setup complexity.Drive transforms your smartphone...
St. John's U Connect
St. John’s U Connect is the personalized concierge service for students, faculty,...
STQRY Guide
Discover stories that bring places to life with the STQRY Guide app—your...
Marshfield R-1 School
The Marshfield R-1 School app provides parents, students, and faculty members with...
