
GRPS
Willow & Oak AB Photo & Video iPhoneiPadiPod touch
GRPS is a free Photo & Video app for iPhone and iPad by Willow & Oak AB. Rated 4.8/5 from 6 ratings. Requires iOS 17.0. Updated October 12, 2026.
- Rating
- 4.8
- 6 ratings
- Price
- Free
- on the App Store
- Size
- 2 MB
- Age 4+
- Updated
- Oct 12
- 2026 · v2.3
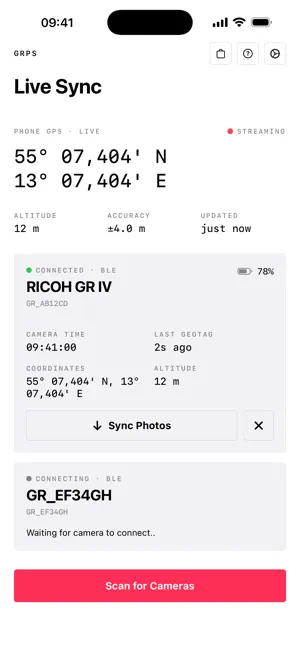
Screenshots

About GRPS
GRPS makes it easy to automatically start and stop location sync from your iPhone to your Ricoh GR III and GR IV cameras. Once the initial connection is made, the app will automatically wake up and start syncing whenever your camera is powered on with Bluetooth enabled within range of the iPhone – even in the background! This allows you to reliably get up to date location information in your images without having to interact with an app, set an explicit duration for location updates or excessively drain your iPhone battery. Basically, set it up once, then forget about it. GRPS also allows you to easily sync your photos to your phone library.
Ratings & reviews
4.8
6 ratings
What’s new
Version 2.3 · Updated October 12, 2026
- Filter Photo Sync by file type: show only JPEG, RAW or video. - Save photos to a folder in Files, including iCloud Drive, instead of the Photo Library. Pick the folder under "Save to". - Downloads now show live progress for each photo, so large RAW files no longer look stuck. - A tidier Photo Sync screen.
App privacy
The developer, Willow & Oak AB, reported these privacy practices to Apple.
Data Not Collected
The developer does not collect any data from this app.
Alternatives to GRPS
Looking for apps like GRPS? Here are 6 similar apps on the App Store. The highest rated is GR Snap - Ricoh GR Image Sync (5.0/5), and 4 of the 6 are free to download.
-
 GR Mint
4.7
-
 Grid: Ricoh GR Companion
3.0
-
 GR Snap - Ricoh GR Image Sync
5.0
-
 GR Viewer for GR2 & GR3
4.2
-
 Grade Recipe Lab
5.0
-
 GRImageViewer
3.3
| App | Rating | Price | Last updated | Compare |
|---|---|---|---|---|
| GRPS | 4.8 / 5 (6 ratings) | Free | October 12, 2026 | |
| GR Mint | 4.7 / 5 (7) | Free | Jul 15, 2026 | Compare |
| Grid: Ricoh GR Companion | 3.0 / 5 (2) | Free | Oct 5, 2026 | Compare |
| GR Snap - Ricoh GR Image Sync | 5.0 / 5 (19) | 9.99 USD | Oct 20, 2026 | Compare |
| GR Viewer for GR2 & GR3 | 4.2 / 5 (216) | 9.99 USD | Oct 19, 2026 | Compare |
| Grade Recipe Lab | 5.0 / 5 (1) | Free | Aug 18, 2026 | Compare |
| GRImageViewer | 3.3 / 5 (43) | Free | Jul 3, 2024 | Compare |
Compare GRPS with the top alternatives: ratings, updates, ASO score and keyword gaps →